南洋理工大学机器人触觉综述:53篇论文梳理感知到控制全链路
论文基本信息 原文标题: Learning Physical Interaction: A Survey of Tactile- and Force-aware Robot Learning 首次公开: 2026年8月2日 署名单位: 南洋理工大学 原论文: https://arxiv.org/abs/2608.07558
LONGGE AI RESEARCH DAILY
每天筛选值得关注的 AI 论文,用工程视角拆解方法、实验和真正的落地价值。
目前已发表 1811 篇文章
论文基本信息 原文标题: Learning Physical Interaction: A Survey of Tactile- and Force-aware Robot Learning 首次公开: 2026年8月2日 署名单位: 南洋理工大学 原论文: https://arxiv.org/abs/2608.07558
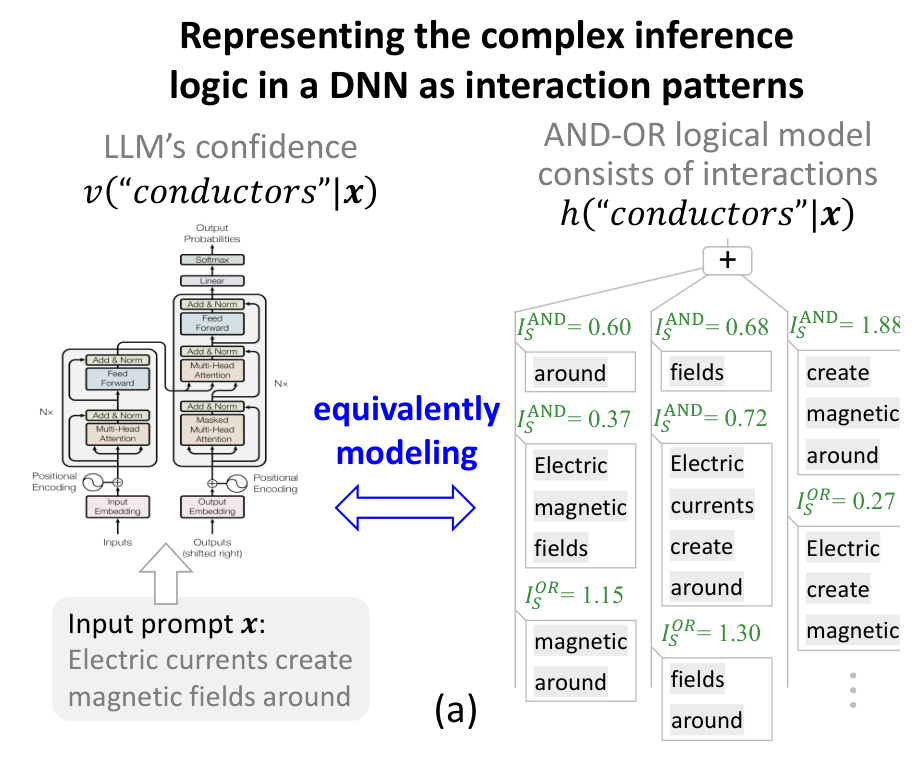
论文基本信息 标题:How Does Parameter Pruning Reshape 深度神经网络(DNN) Representations? An Interaction-Driven Exploration 首次公开时间:2026年9月6日 署名单位:上海交通大学 原论文链接: https://arxiv.org/abs/2609.06483 项目与
论文基本信息 原文标题: 显式概念记忆方法(ECoMEM):面向记忆依赖的机器人控制 首次公开: 2026年9月30日(arXiv v1) 署名单位: 斯坦福大学 原论文链接: https://arxiv.org/abs/2610.00801 项目页面: https://ecomem.github.io/
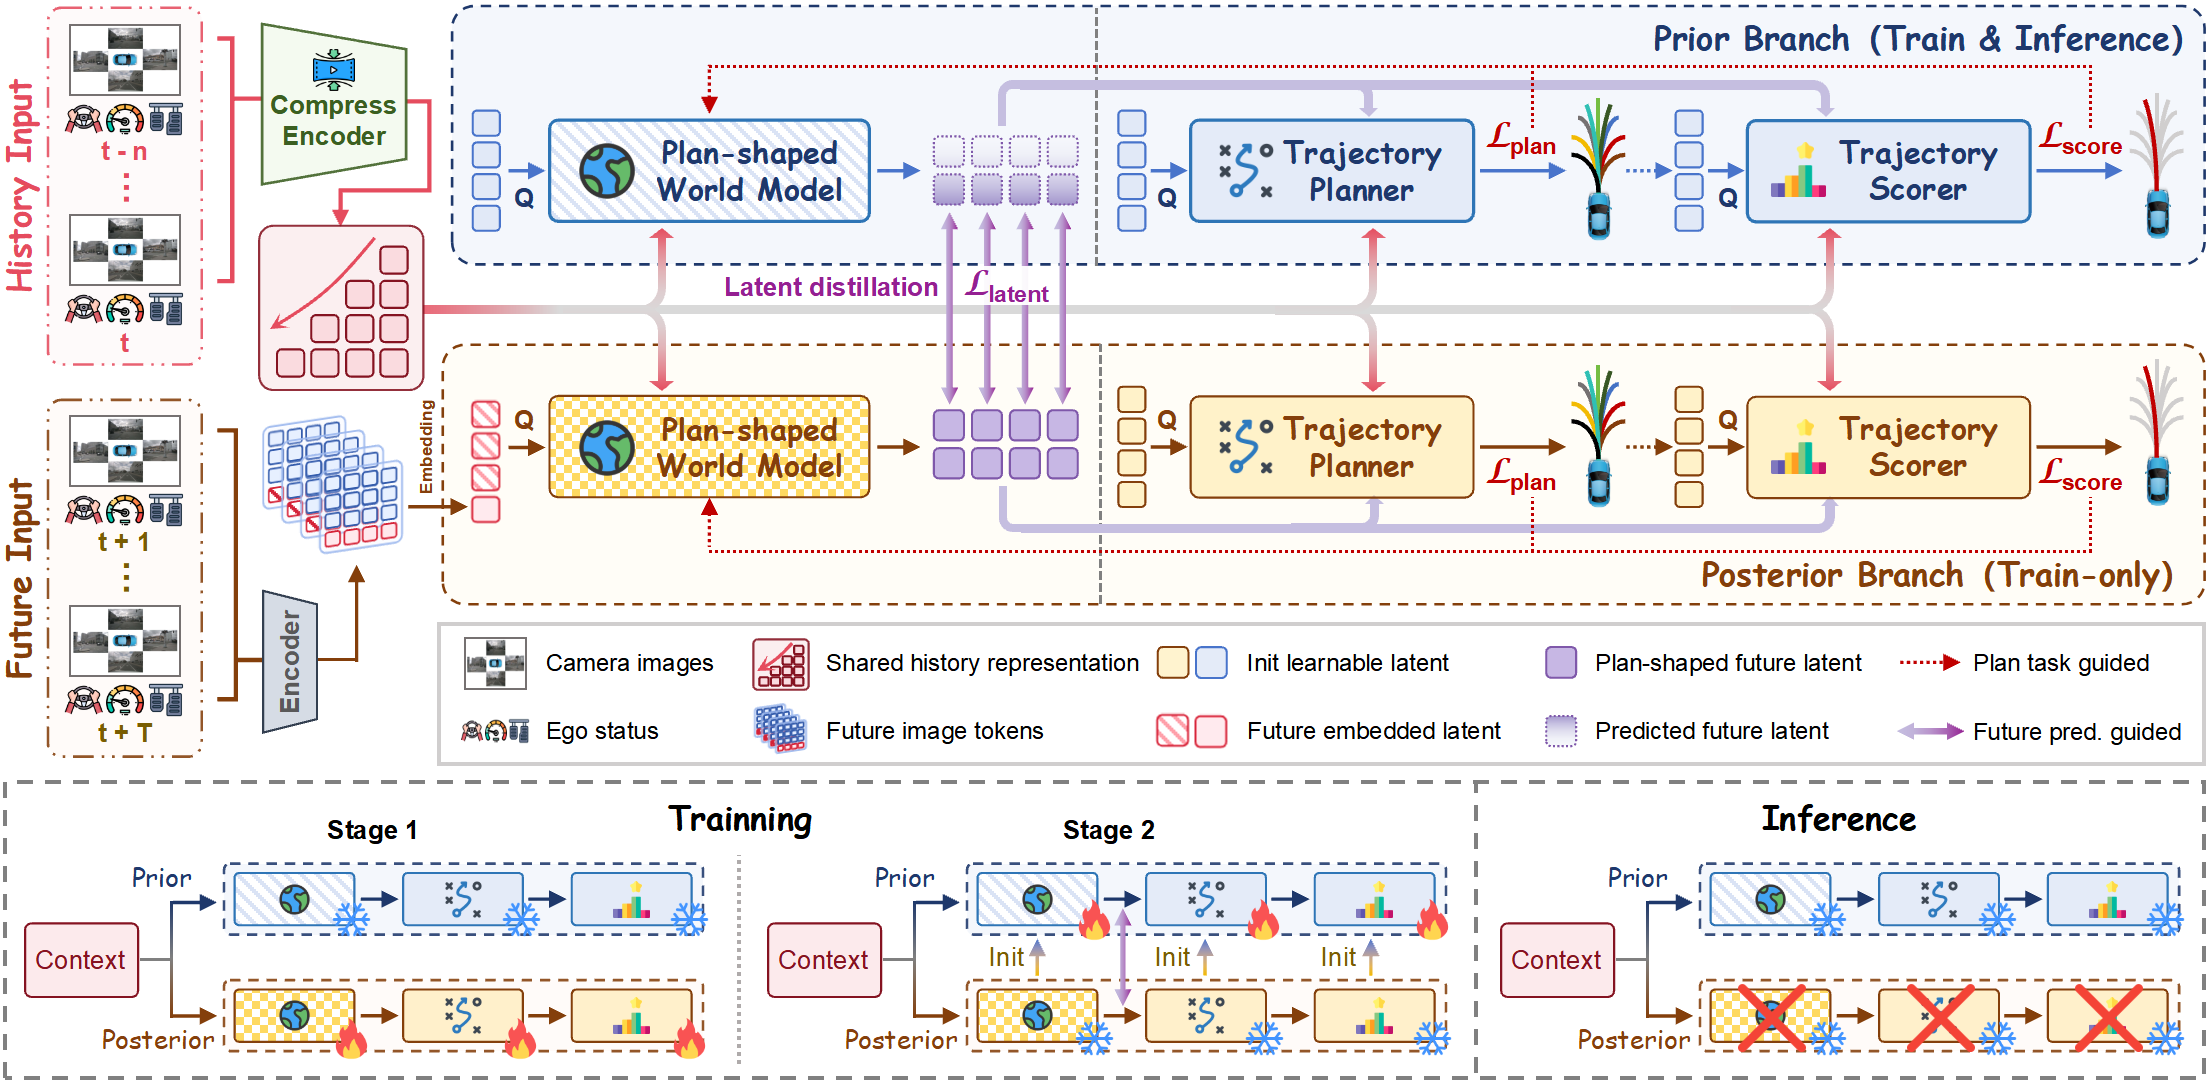
论文基本信息 文中简称说明:规划塑形未来表征模型(PlanWAM);由规划任务塑形(Planning-Shaped);端到端(End-to-End)。 原文标题: PlanWAM: Planning-Shaped Future Representations for End-to-End Autonomous Driving 首次公开: 2026年10月8日
论文基本信息 原文标题:Parason: Revealing Subtask and Trial Parallelism in LLM Reasoning(其中LLM指大语言模型) 署名单位:清华大学、麻省理工学院、NVIDIA 首次公开:2026年8月25日 https://arxiv.org/abs/2608.24658
论文基本信息 原文标题: Copying explains the collective behavior of AI agents in the wild 首次公开: 2026年9月8日 署名单位: 康斯坦茨大学、恩里科·费米研究中心、意大利联合圣保罗银行数据与人工智能办公室、维也纳复杂性科学中心 原论文链接: https://arxiv.org/abs/
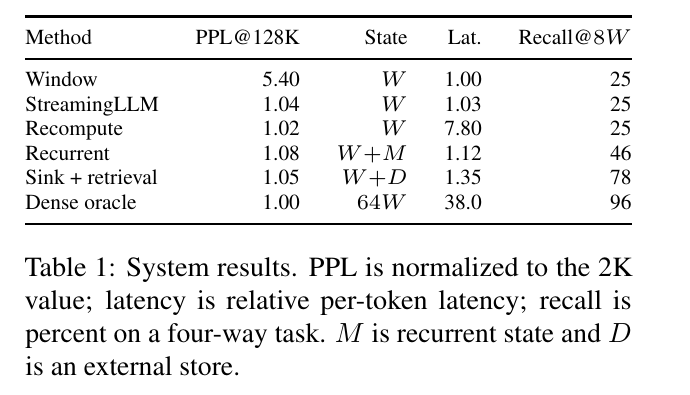
论文基本信息 原文标题: Separating Stream Stability from Long -Term Recall in Language Models 首次公开: 2026年9月7日 署名单位: 广西大学、重庆交通大学、广东工业大学 https://arxiv.org/abs/2609.07282
论文基本信息 原文标题: P r i v E s c a l a t e : Measuring and Augmenting the Threat of L L M - A u t o m a t e d Linux Privilege Escalation 首次公开: 2026年9月8日 署名单位: 新加坡南洋理工大学、西安交通大学 会议: 2026年计
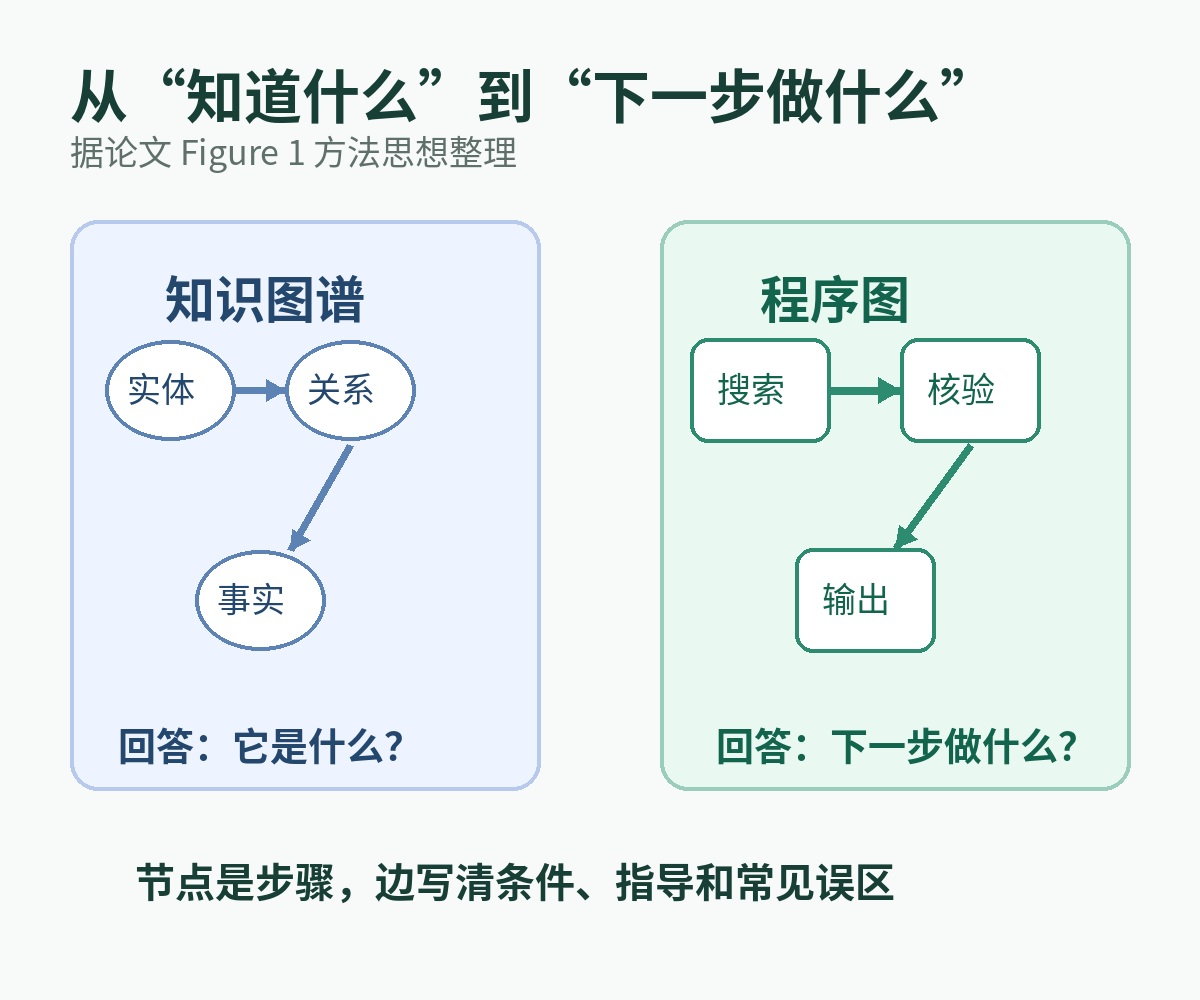
原文标题: Procedural Graphs: Self- Evolving Execution Structures for L LM Agents 首次公开: 2026年9月8日(arXiv v1) 署名单位: 谷歌、佐治亚理工学院、北京大学 研究领域: 大语言模型智能体、工具调用、长程规划、程序性记忆 原论文: https://arxiv.org/a
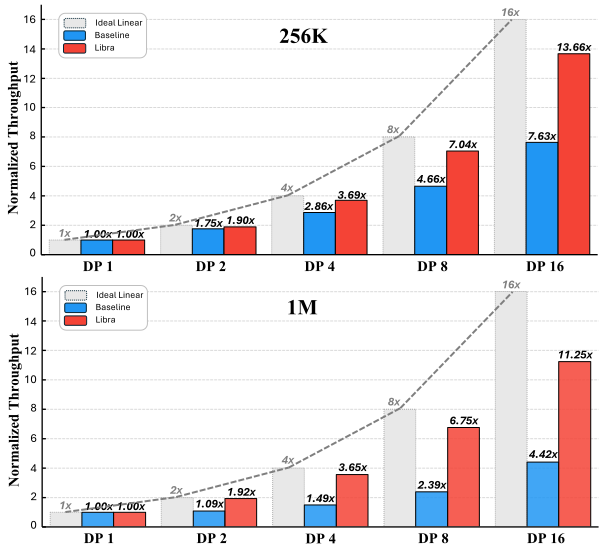
原文标题: Libra: Taming Attention Workload Skew in Long-Context LLM Training with Bounded Sequence Pool 首次公开: 2026年7月25日 署名单位: 中国科学院大学、阿里巴巴集团、新加坡国立大学 核心术语: 长上下文训练(Long-Context)、大语言模型(L
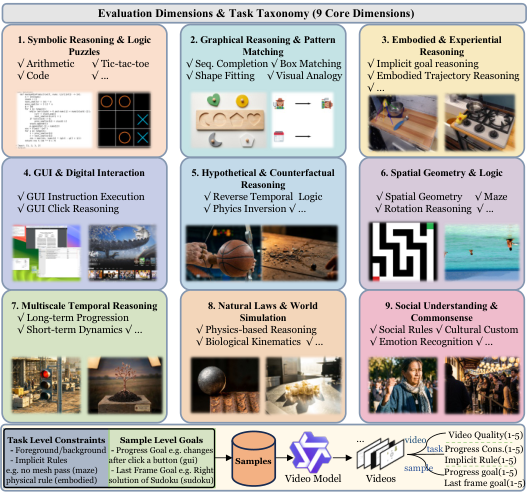
原文标题: “以视频思考”方法(Think-with-Video)对应原文题名:From Evaluation to Enhancement: Benchmarking and Improving Think-with-Video Reasoning for Video Generative Models 首次公开: 2026年9月10日 署名单位: 新加坡
原文标题: VISTA: A Visual Harness for Reasoning in an Interactive World 首次公开: 2026年10月1日 署名单位: 麻省理工学院 知名研究者: 何恺明团队 原论文: https://arxiv.org/abs/2610.02200 项目主页: https://vista-research.gi
LONGGE AI COMMUNITY
加入「龙哥读论文」知识星球,持续获取 AI 论文、资讯、开源项目、招聘与研究思路。
加入龙哥读论文微信群:添加微信 kangjinlonghelper,备注“研究方向 + 地点 + 学校/公司 + 昵称”。
 微信扫码加入知识星球